ON MY WALL, FIGURATIVELY
A whole field.
Still so much to explore.
I love this map of computer science. There’s something wonderful about seeing the connections laid out in one place.
Software Systems Engineer at ASM
Full-stack software systems engineer working across Python, robotics, ML pipelines, and application development for semiconductor manufacturing. Co-author on distributed deep learning research published at ACM SIGSPATIAL 2025.
Phoenix, AZ — open to remote and relocation
A SMALL HUMAN ON THE INTERNET
Hi, I'm the smaller Autrin. Same mustache.
Things I've built. My tiny colleague has opinions—tap him.
Published at ACM SIGSPATIAL 2025. Spatiotemporal model combining a Transformer temporal encoder with dual GAT-GRU spatial branches over flow and catchment edges, treating every land and river pixel as a graph node. Distributed training across 64 NVIDIA A100 GPUs on NERSC Perlmutter delivered 15× speedup. State-of-the-art performance against five baselines (NSE: 0.97, KGE: 0.96).
At ASM
Production application driving a robotic measurement fixture for
semiconductor components: robot motion, air-flow measurement,
camera inspection, and a full operator HMI. Owned end to end -
measurement algorithms, safety and recovery flows, SQLite data
layer, automated validation (140+ tests), and Windows installer
deployment to international manufacturing sites.
At ASM
Full-stack system linking component measurement data with
equipment data: JavaScript/HTML/CSS frontend, Python services,
AI/ML similarity and quality-estimation models. Saves engineers
hours of manual lookup and lays the data foundation for
equipment-aware analytics.
At ASM
Operator-facing control software shipping with a seven-figure
robotics product: touchscreen workflows, threading so robot
motion and live camera feeds never freeze the UI, recovery and
safety handling, packaged field deployment. UI rebuild
contributed to a quarterly team award.
Industrial visual inspection built with PatchCore, Anomalib, and FastAPI. Detects anomalies and highlights suspect regions, with optional local Qwen3-VL reports through Ollama that cannot override detector decisions. On a 63-image MVTec AD bottle evaluation with separate training and calibration sets, detected all 48 defects with no false alarms across 15 clean images, averaging 0.30 seconds per image on an RTX 4070 Laptop GPU. Features schema-constrained VLM output, taxonomy validation, fail-safe parsing, and a reproducible evaluation harness for detection, localization, and inference cost. Includes an interactive inspection console and 145 accelerator-independent tests. Current focus: sharper localization and validation across more product categories.
Autonomous robotic system using a UR10e arm with computer vision and the Stockfish chess engine. Built the perception pipeline (AprilTag detection, board state estimation), the motion planner with safe approach patterns, and adaptive difficulty driven by engine depth.
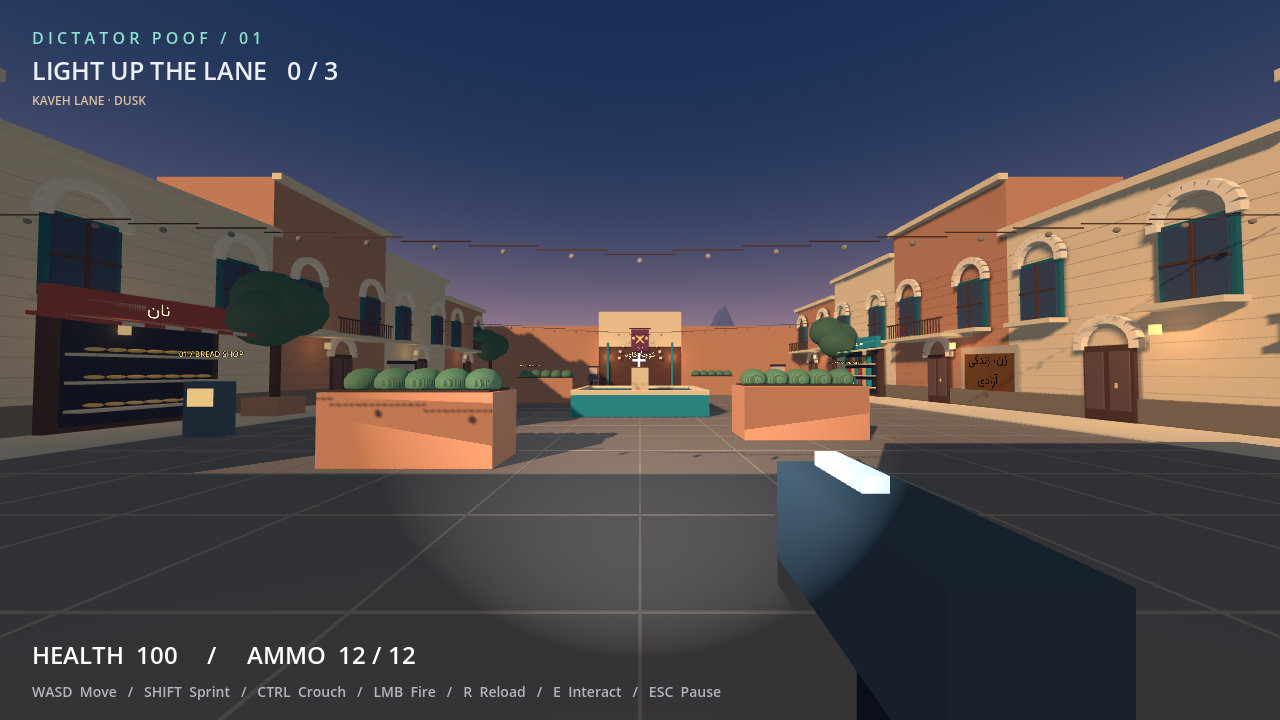
In development · Godot 4 / GDScript
Open-source first-person resistance game set in a fictional
Iranian neighborhood, exploring freedom and everyday life under
authoritarian rule. Restore power to the street while evading
or fighting patrols, then join friends in the illuminated
courtyard. Built with procedural 3D environments, A* patrol
pathfinding, raycast combat, mission-driven lighting, and
English/Persian localization with right-to-left text support.
Includes automated integration checks for core gameplay.
Implemented queue-based Round-Robin and Stride schedulers in the xv6 operating system on RISC-V. Worked through context switching, spin locks, and process synchronization, with tests written first to validate correctness against the existing kernel.
Concurrent encryption pipeline in C using pthreads, POSIX semaphores, mutexes, and condition variables. Five parallel stages communicate through bounded buffers, with careful attention to deadlock avoidance and throughput under contention.
Reliable transport protocol in C over TCP, implementing CRC error detection, ACK/NAK-based retransmission, and a sliding window. Tested under simulated packet loss and reordering to verify correctness of the recovery logic.
Android application for Iowa State students and faculty. Features class schedules, real-time chat, an AI-powered Q&A assistant, weather, and a friend-suggestion system. Built end-to-end including the backend service and database design.
Working through libp2p, IPFS content addressing, and a small mesh networking simulation in Python and Rust. A sandbox for understanding peer-to-peer and content-addressed protocols from first principles.
A small autonomous car project built on an RC chassis. The planned stack connects perception, localization, planning, and control on a Raspberry Pi, with lane following and obstacle avoidance as development goals. Designed around modular interfaces, recorded-data replay, automated tests, and a safety layer between control commands and the hardware.
I'm Autrin, a Software Systems Engineer at ASM in Phoenix, where I build inspection tooling, robotics workflow platforms, and internal applications across backend and frontend. My day-to-day spans Python and Flask services, Tkinter and JavaScript interfaces, SQL data layers, and ML-driven inspection.
Before that, I co-authored HydroGAT, a distributed deep learning system for flood prediction trained across 64 A100 GPUs on NERSC's Perlmutter supercomputer, presented at ACM SIGSPATIAL 2025.
What I enjoy: getting hardware and software to cooperate, designing systems that hold up under real load, and the moment a complex pipeline finally works end-to-end. I'm looking for roles in robotics, distributed systems, applied ML, or full-stack software — anywhere the work touches real systems and the bar is correctness, not just velocity.
Designing across services, interfaces, and infrastructure as one coherent whole
Learning in public and contributing back to the tools I rely on
Measure first, then optimize; benchmarks over hunches
Picking up whatever the problem requires, then going deeper
OFF THE CLOCK
A sky worth stopping for. A map that makes me want to keep learning.
ON MY WALL, FIGURATIVELY
I love this map of computer science. There’s something wonderful about seeing the connections laid out in one place.
Interested in collaborating, hiring, or just talking shop about robotics, distributed systems, applied ML, or full-stack software? Reach out.